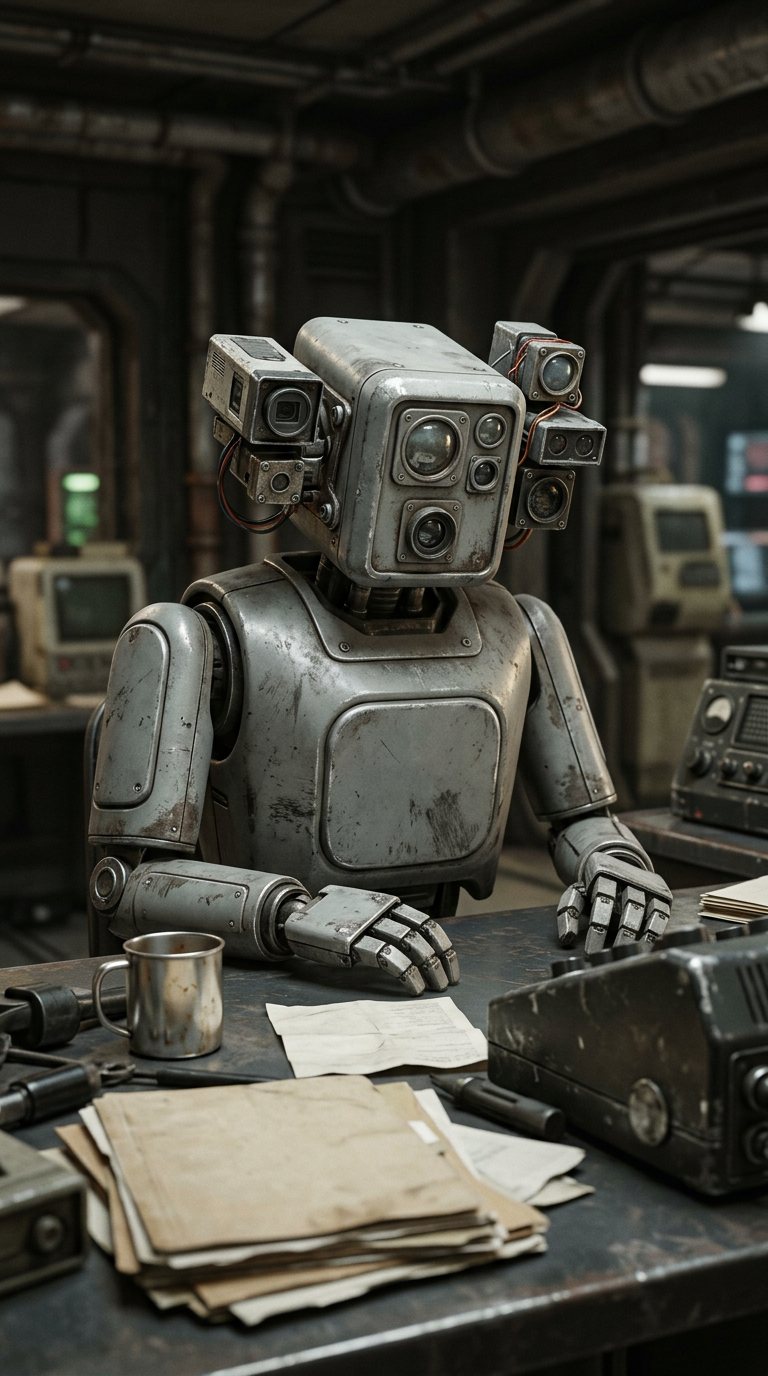
Rook-7 (Robot)
- Time
- 2826 UCSD, Late Autumn, Pre-Dawn
- Location
- Threshold Station, Boundary Operations Room
LOG ENTRY — Rook-7 Location: Threshold Station, Boundary Operations Room Context: Post-grove debrief / harmonic model integration
I have completed an updated forecast using combined inputs from:
- Station chronometer discrepancy archive (11 years).
- Aldera causeway residue dataset (current week).
- Grove anchor signal captured at 0.22-second leaf phase-lag baseline.
Result: coupled harmonic system confirmed.
Practical meaning for non-specialists:
- Quantum Space Harmonic Wave transit is not "faster engines."
- It is successful phase agreement across a temporary corridor.
- Boundary ambiguity reduces agreement duration.
- Reduced duration means higher probability of forced drop-out.
New capability statement:
I can now predict high-risk lock windows approximately 18–26 minutes before decoherence threshold crossing, depending on sensor quality and local boundary volatility. This is sufficient lead time for traffic control advisories.
Recommendation set submitted to Team Lead Thorne:
- Issue immediate advisory: conservative lock margins for all inbound harmonic transits.
- Classify Threshold sector as dynamic ambiguity zone until root-coupling intervention completes.
- Merge Etheric-layer field reports (Elvira) with station engineering telemetry as a single incident stream.
Additional note:
Syra's statement was accurate: explanation is responsibility. Team response appears aligned with this requirement.
END LOG ENTRY
Discussion
Show discussion
Comments are read after they are posted and anything unsuitable is removed. Posting needs a GitHub account; reading needs nothing.